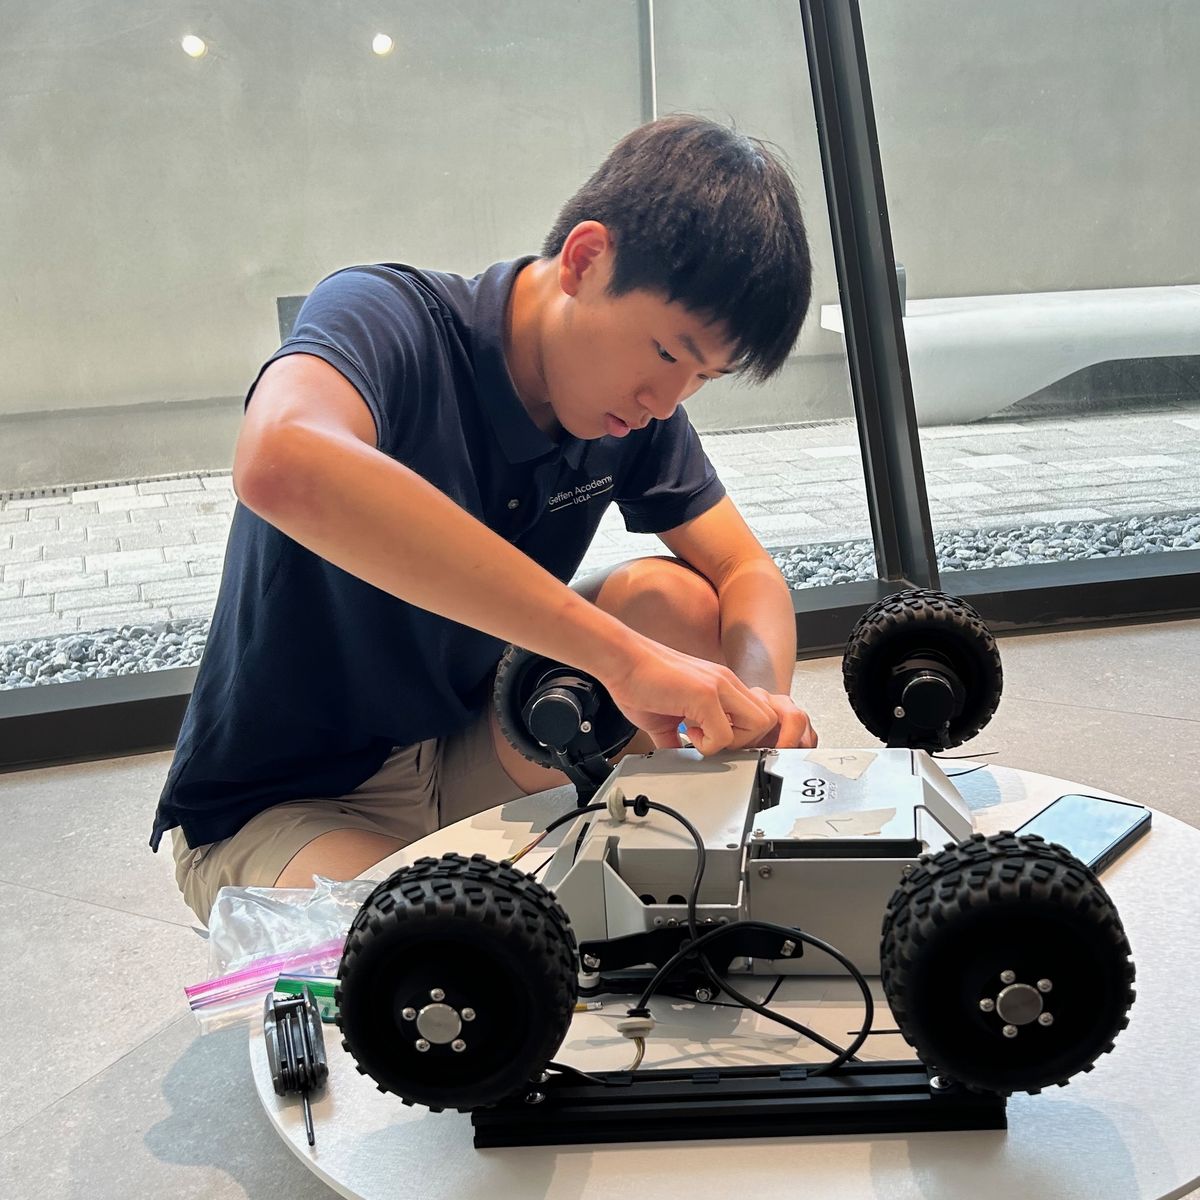
I’ve always loved robots.
Some of my earliest memories are of playing with robots—moving their arms and legs, tightening screws, and trying to understand how they worked.
When I was 13, I began working at UCLA’s Robotics & Mechanisms Laboratory (RoMeLa). That was when playing with robots became actually building them.
Since then, I’ve worked on humanoid robots, computer vision, robot soccer, educational robots, and research projects alongside undergraduate and graduate students.
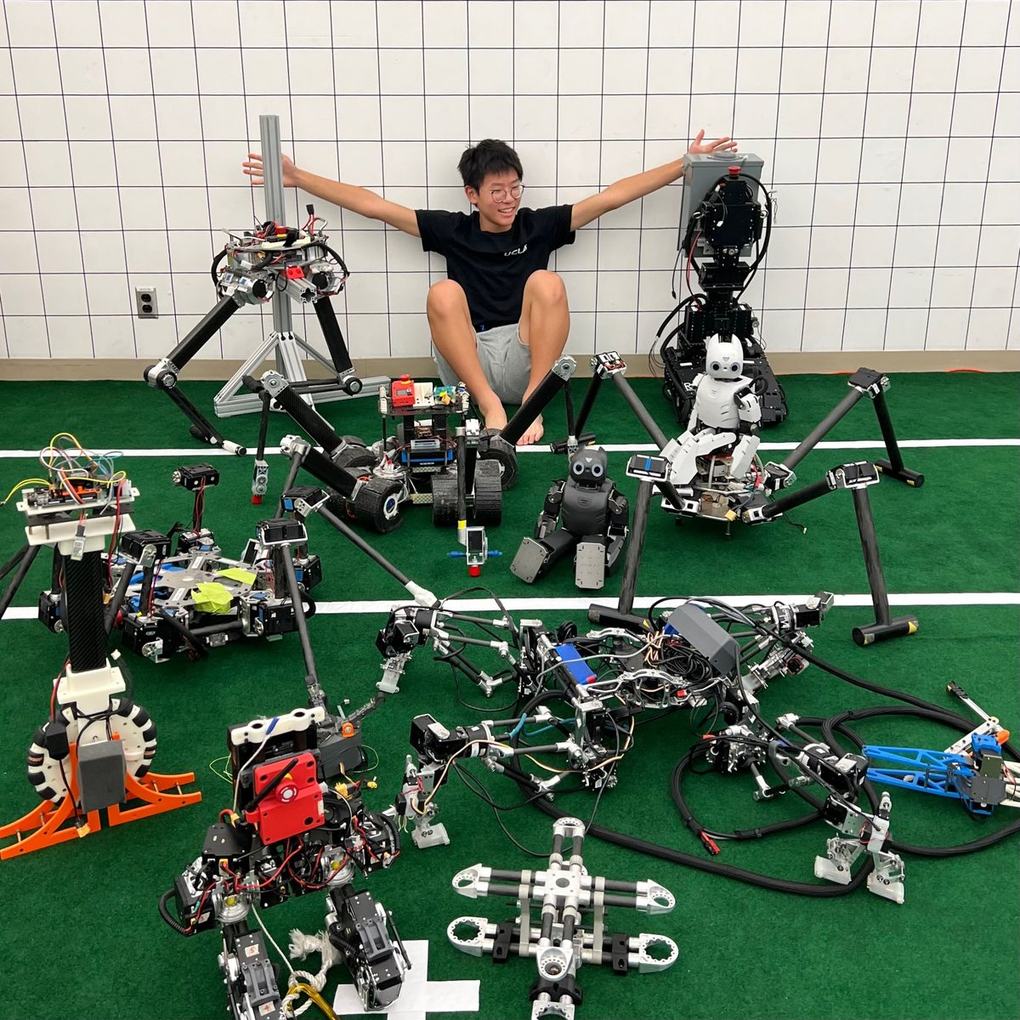
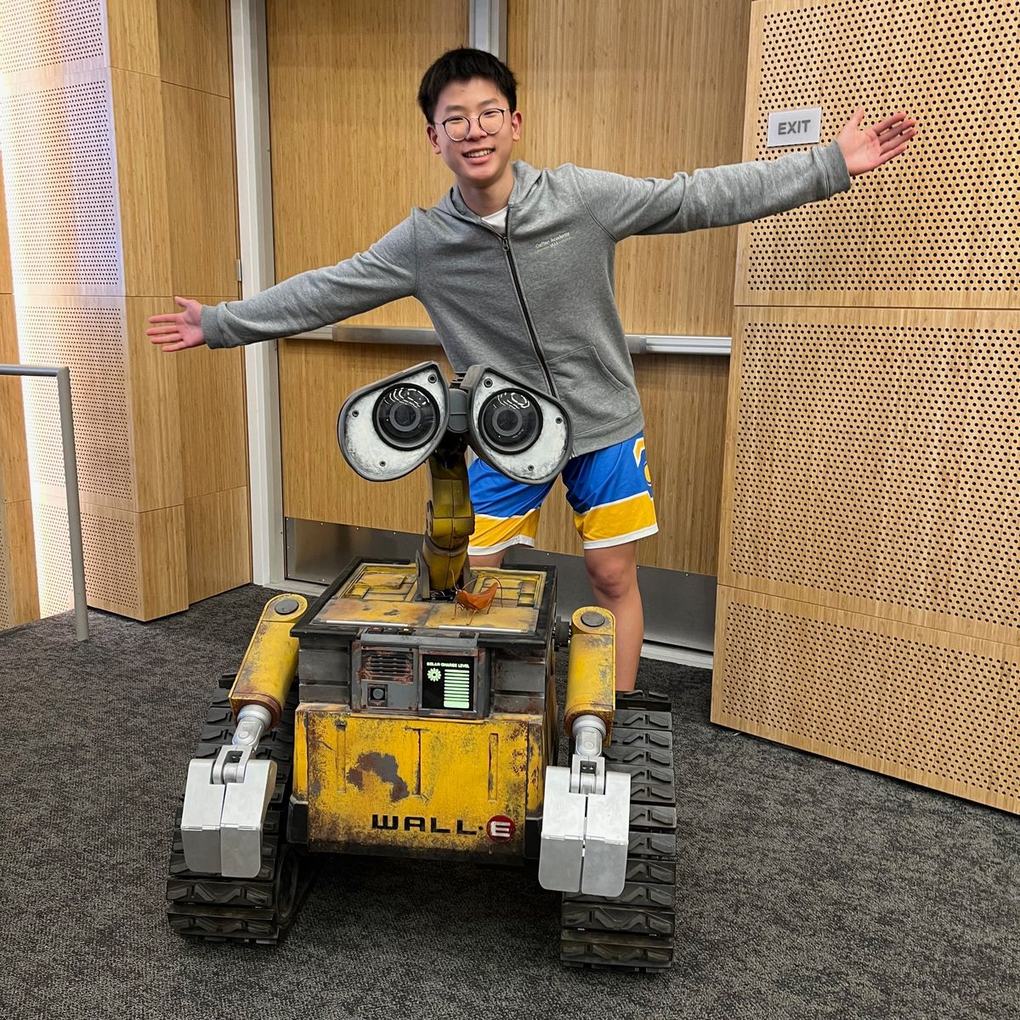
What I enjoy most is the process:
Build something, test it, figure out why it doesn’t work, and try again.
ARTEMIS & RoboCup
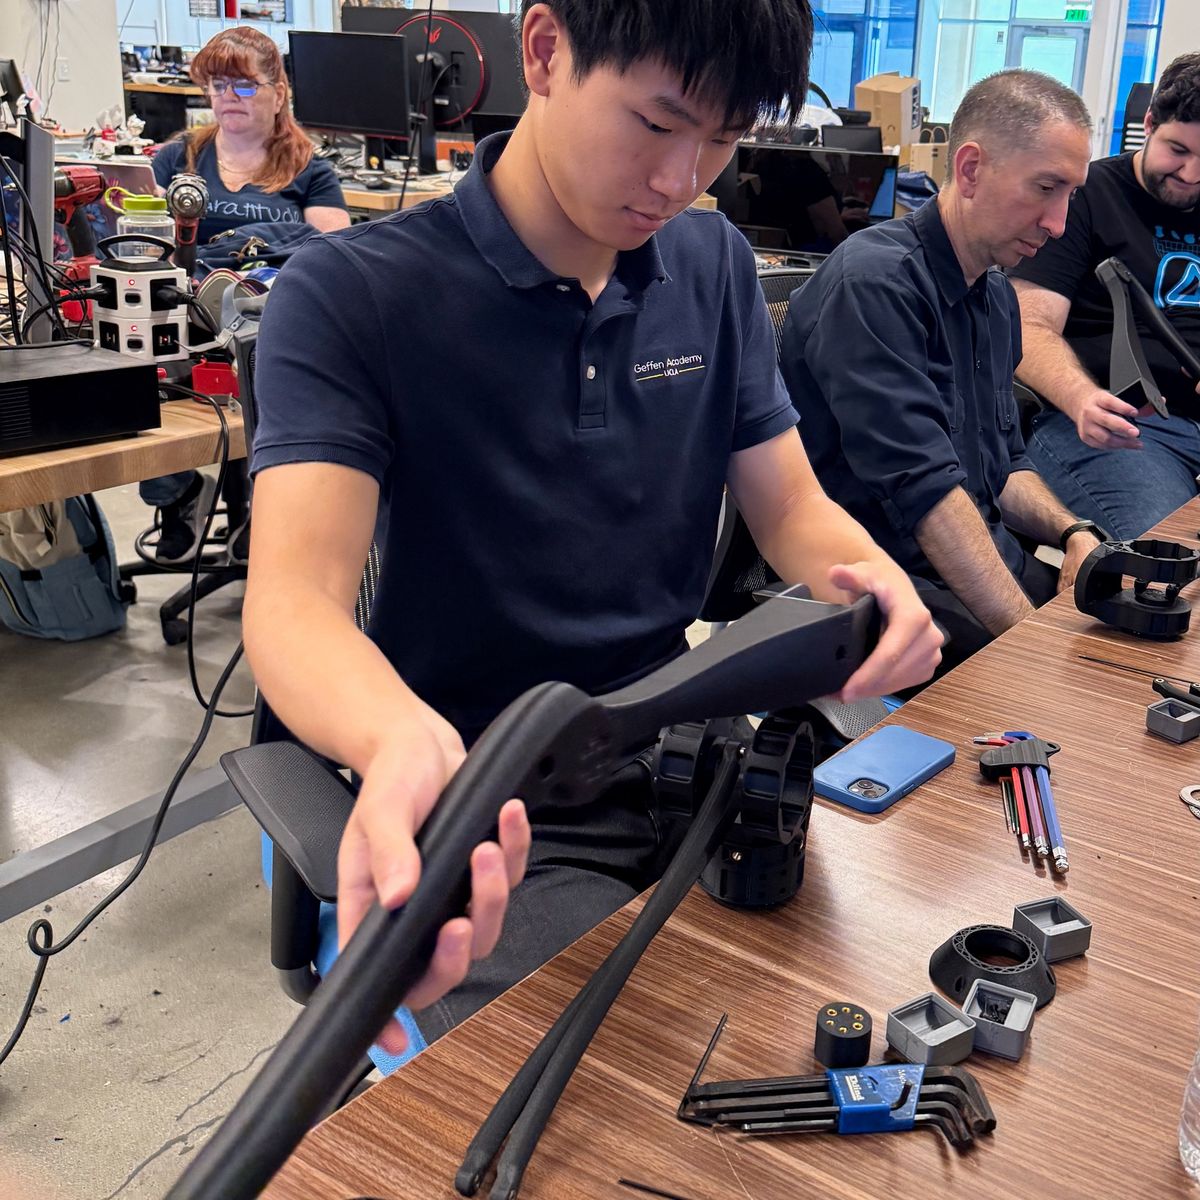
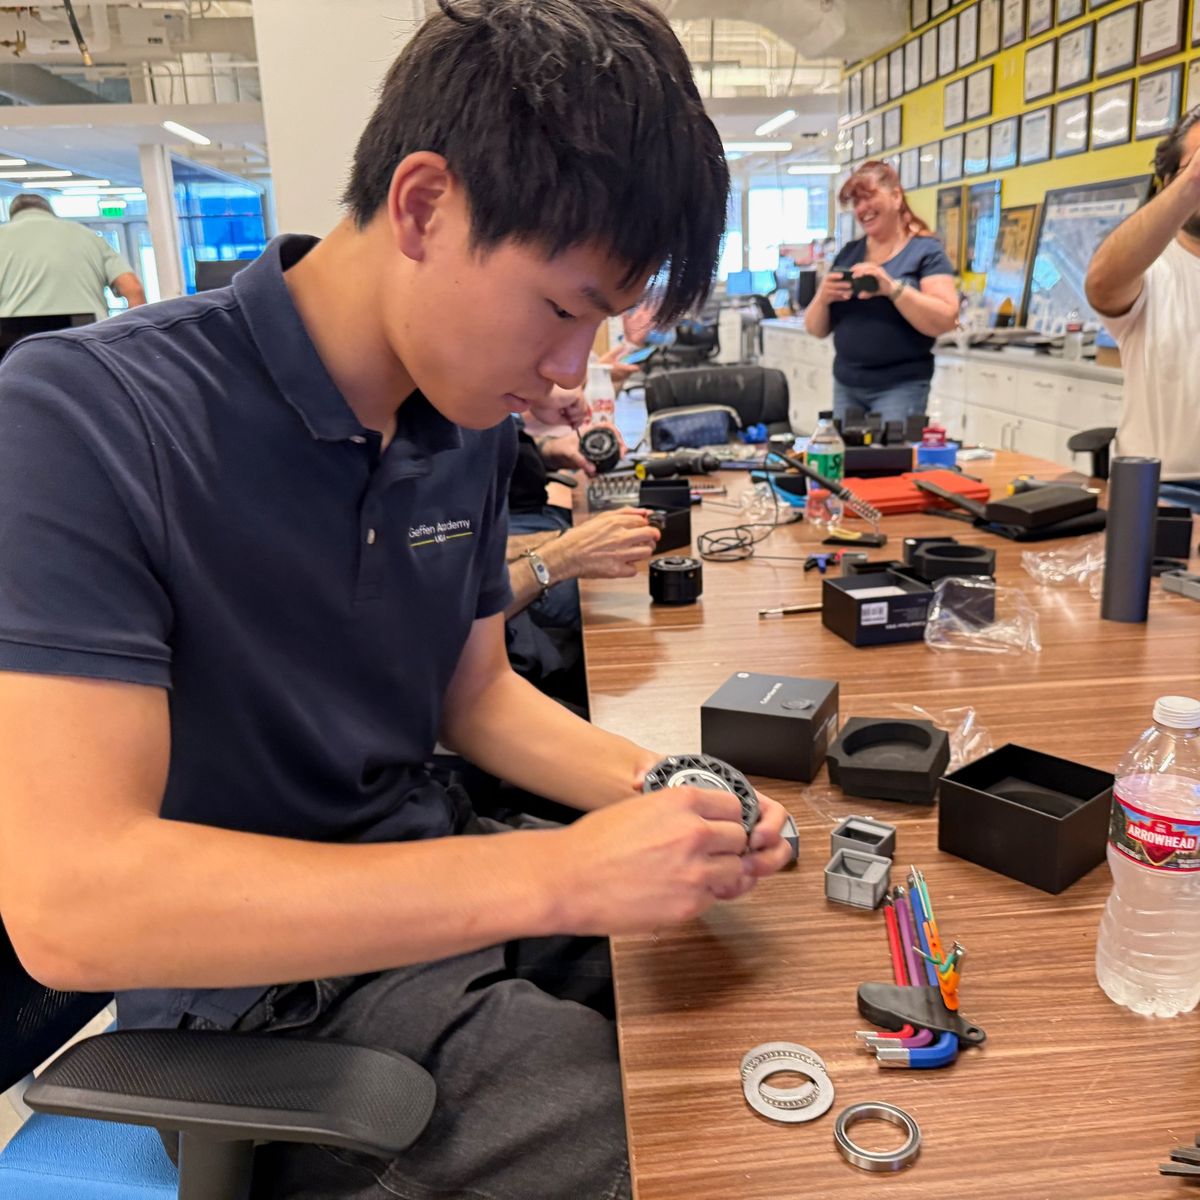
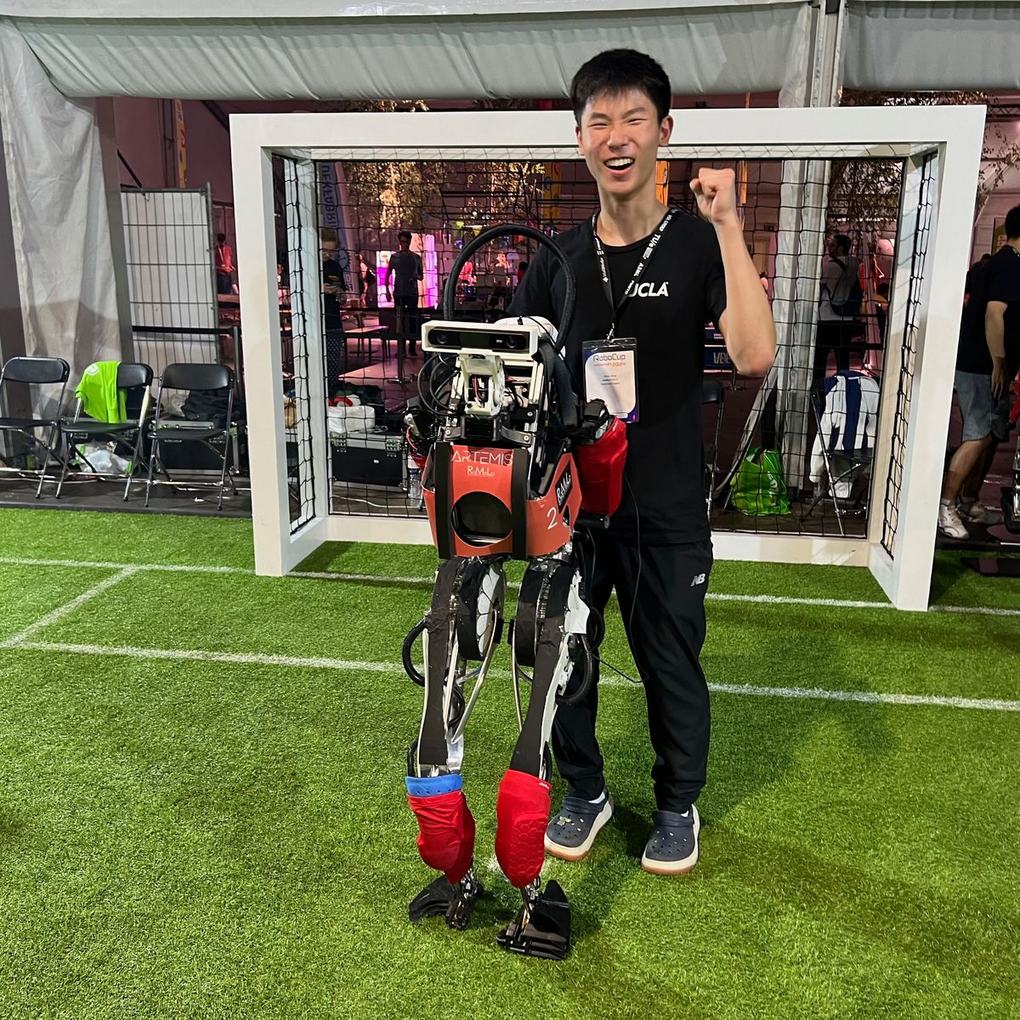
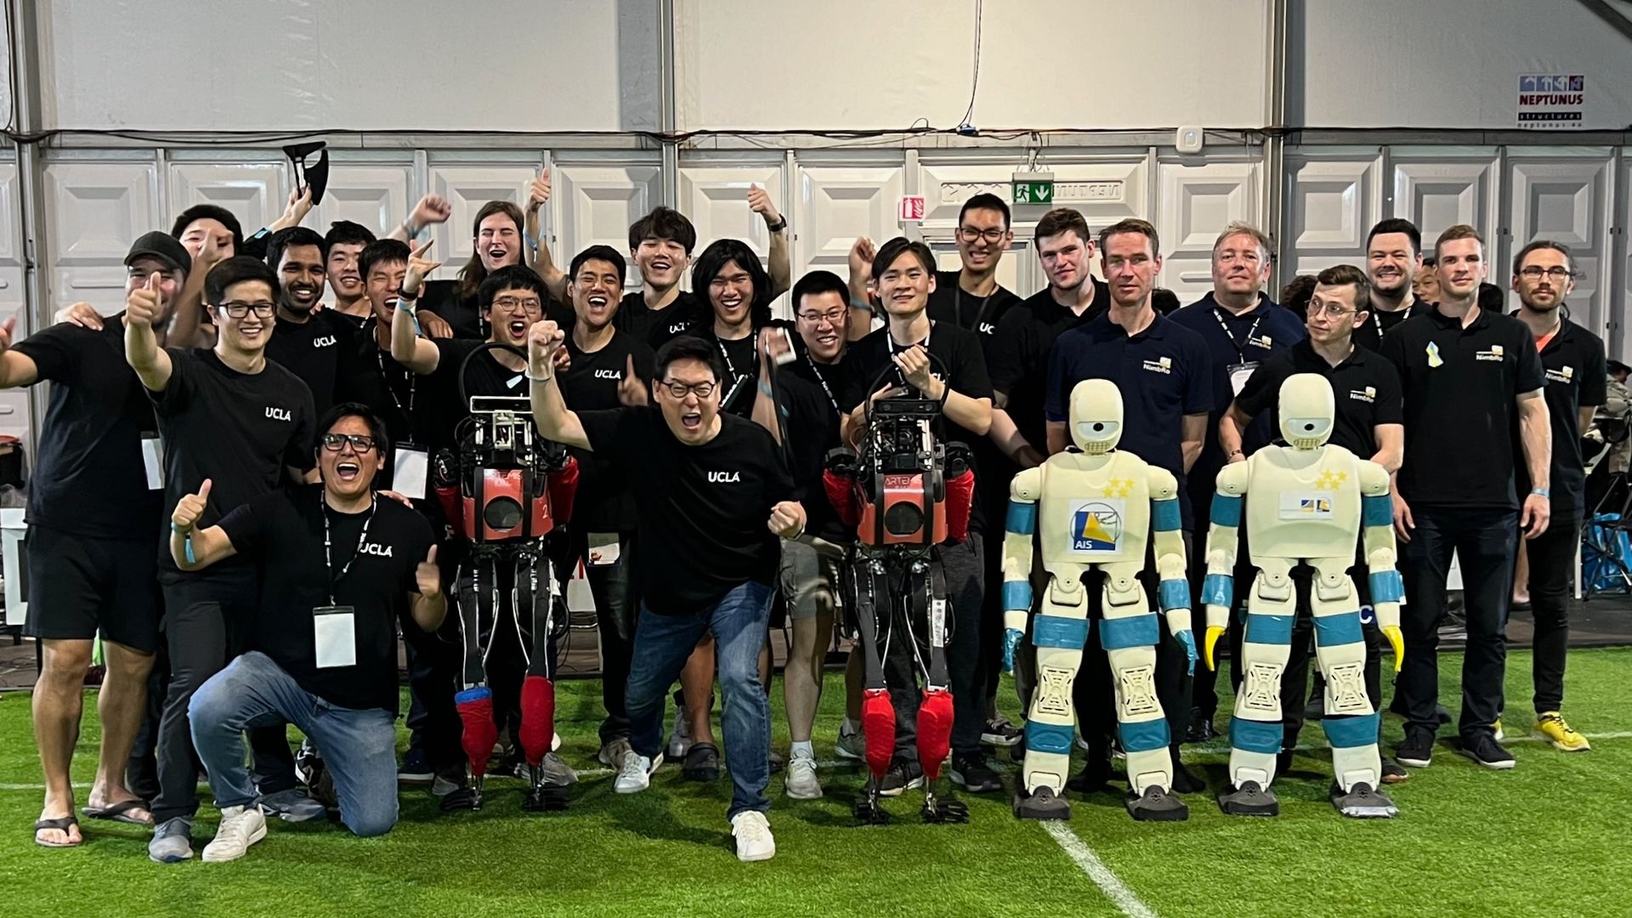
A big part of my time at RoMeLa has been working with ARTEMIS, our full-size humanoid robot and robot soccer player.
I’ve contributed to the team in areas including vision data collection and annotation, robot testing, and hardware development. I also designed and built an early prototype of ARTEMIS’s head.
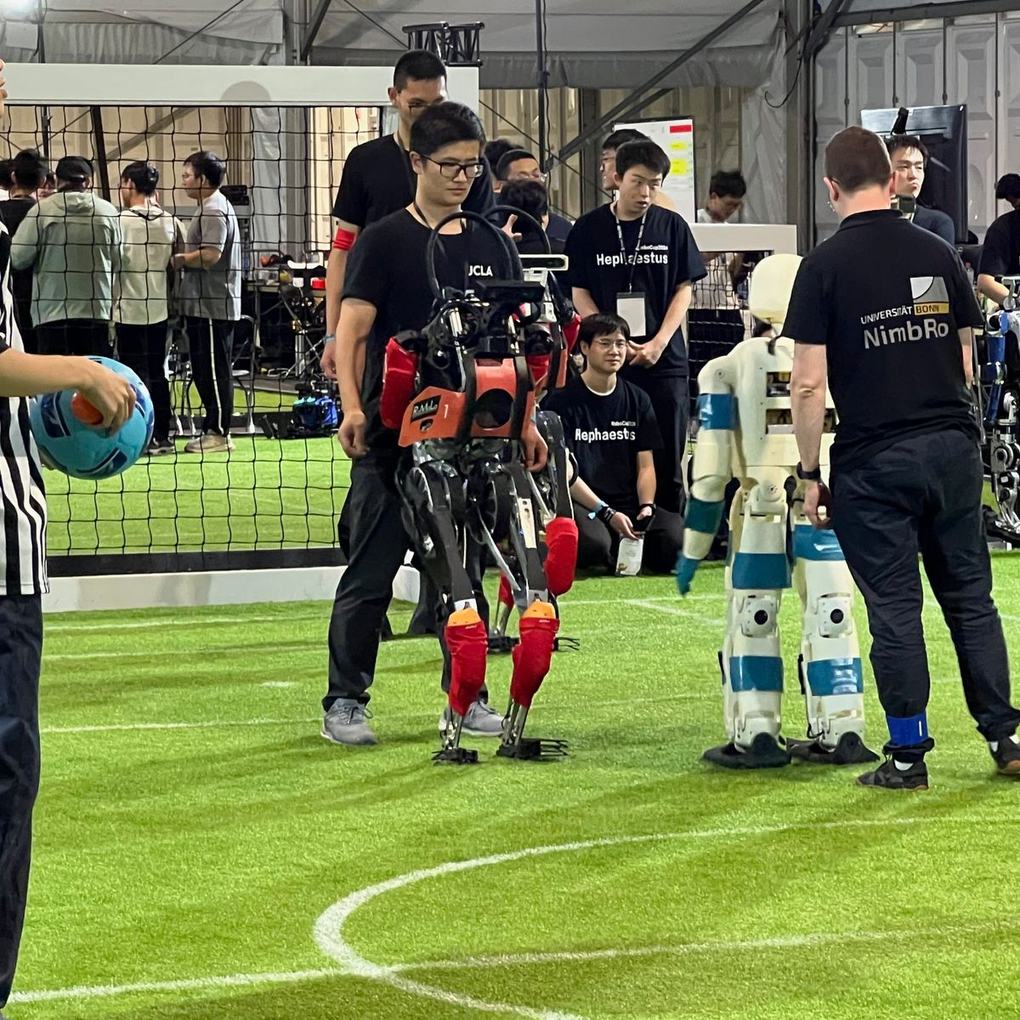
Robotics becomes very different when a robot has to perform outside the lab. At RoboCup, everything has to work together—mechanical systems, electronics, perception, control, software, and the people operating and repairing the robot.
Teaching a robot to see
A soccer robot can only play what it can see. To train ARTEMIS’s vision, we photograph the field from the robot’s point of view, then label the ball, the lines, the corners, and the penalty marks in every image, one by one.
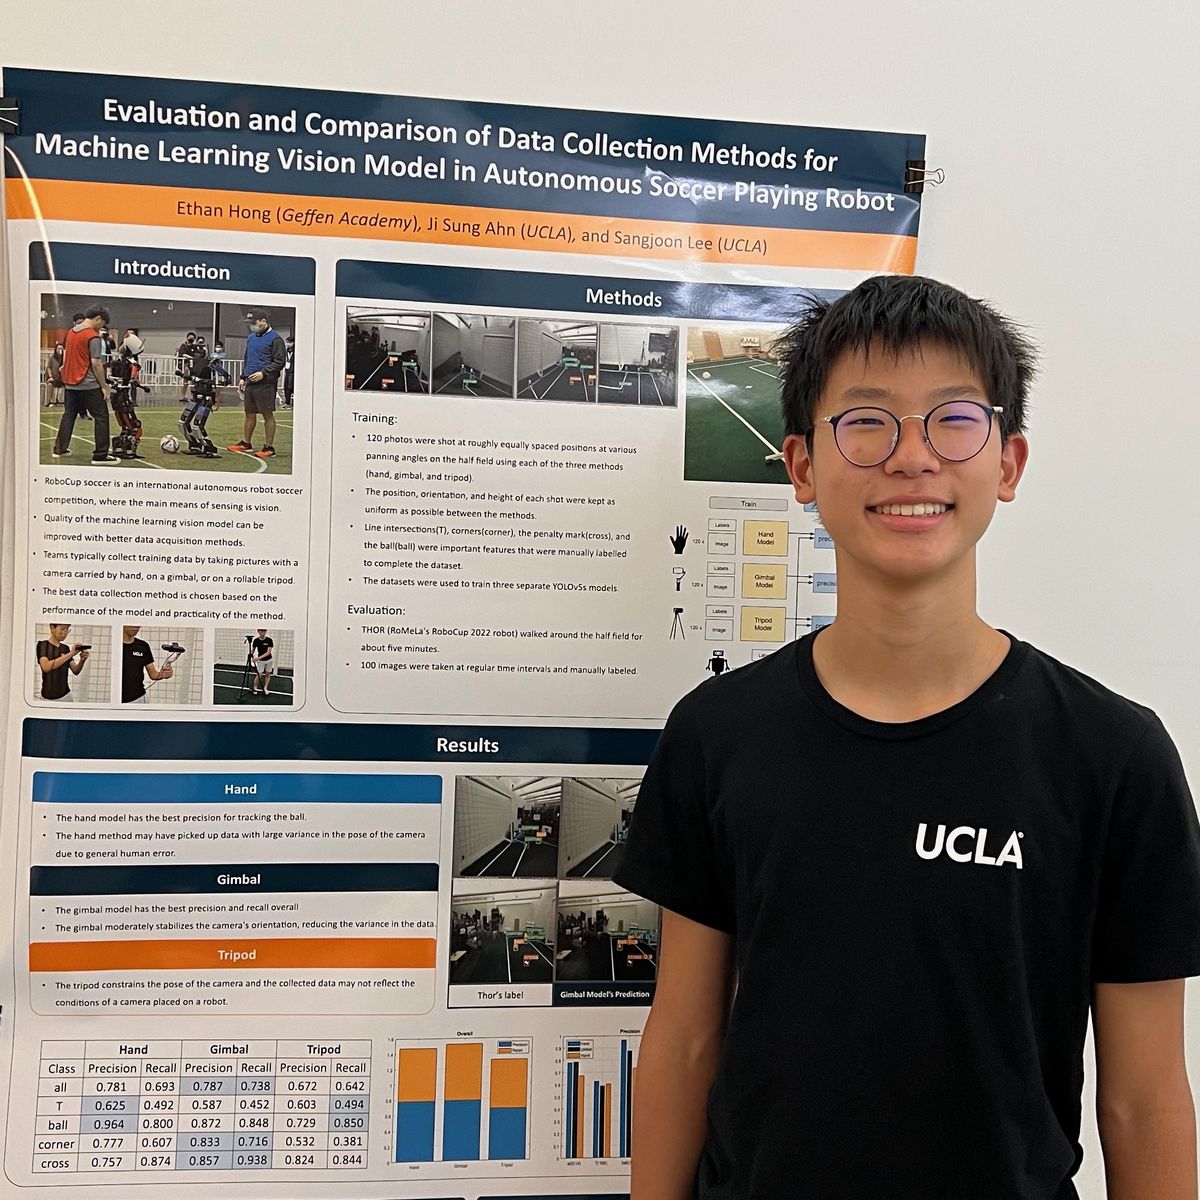
That work became my first research question: does it matter how you collect those pictures? I compared three methods—by hand, on a gimbal, and on a tripod—and trained a separate vision model on each. The gimbal gave the best results overall.
I presented the results at the Southern California Robotics Symposium in 2022, where the poster won the People’s Choice Poster Award. I later expanded it into a first-author paper at UR2025.
See the research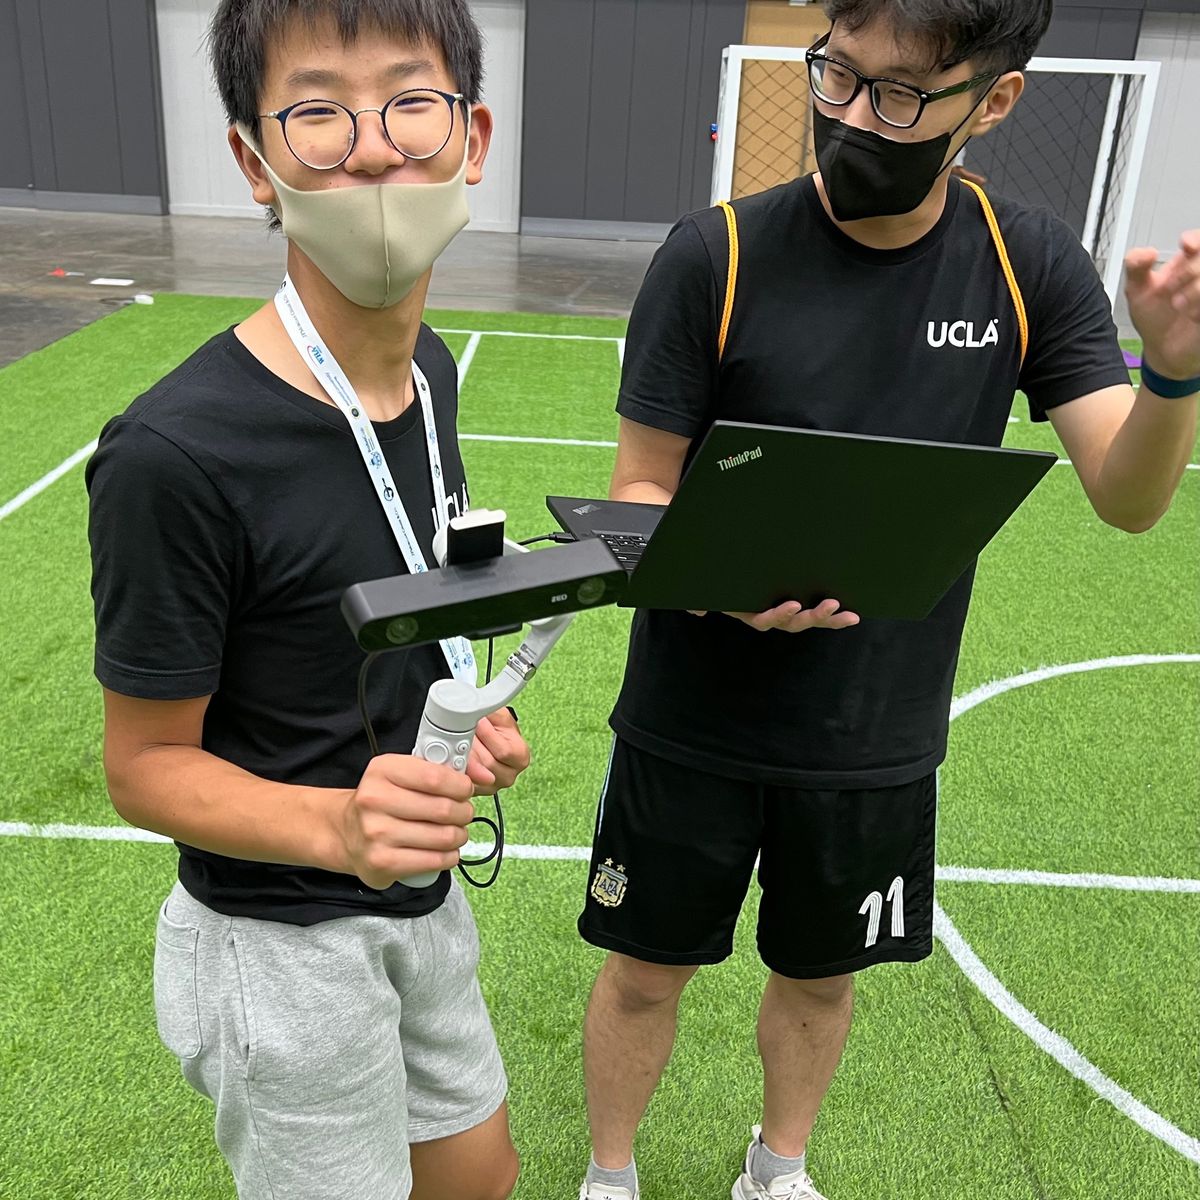
Three RoboCups
- 2022
 Bangkok, Thailand
- 2023
 Bordeaux, France
- 2024
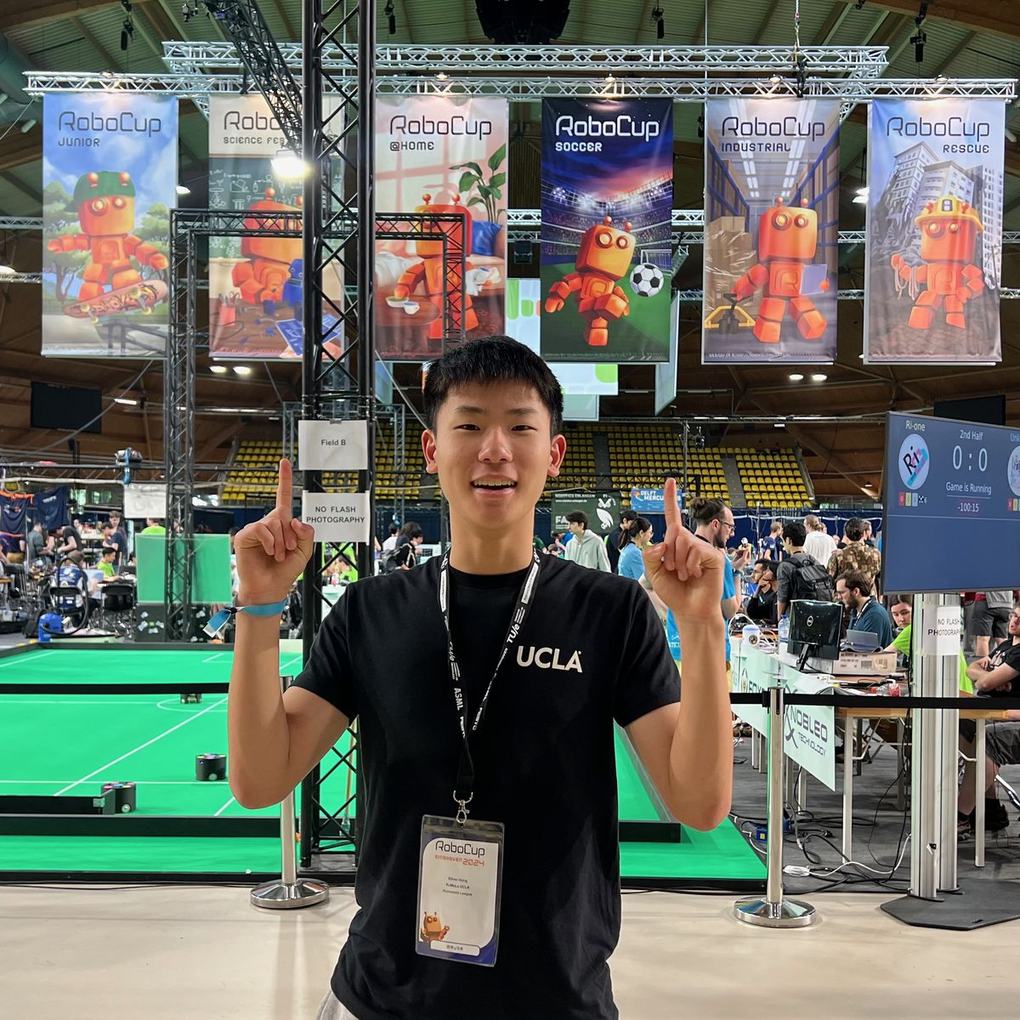
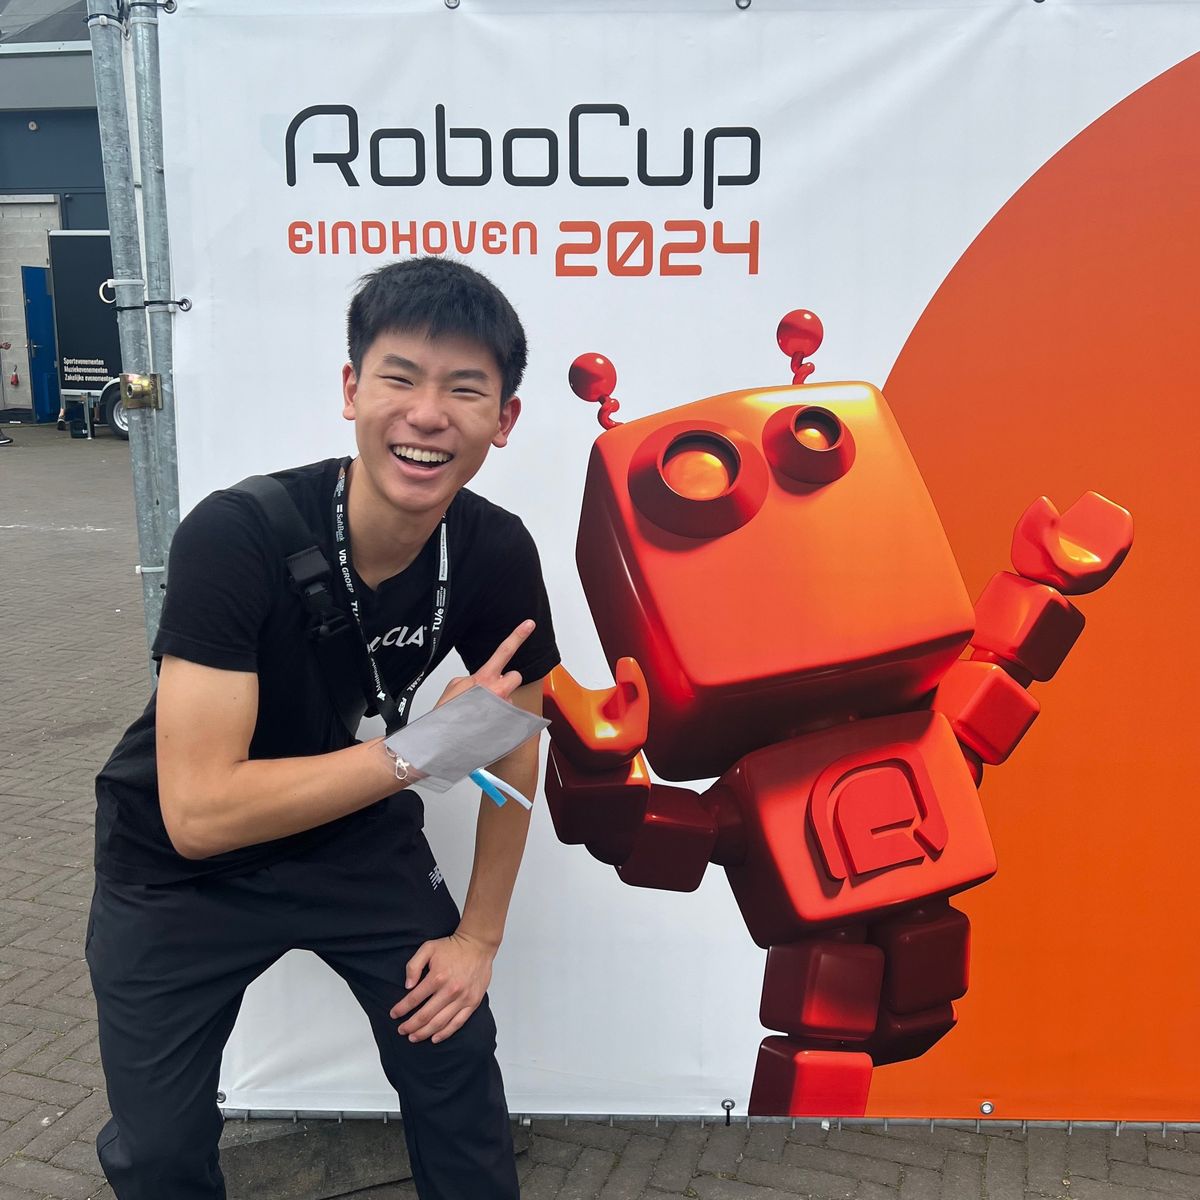
 Eindhoven, NetherlandsWorld Champions
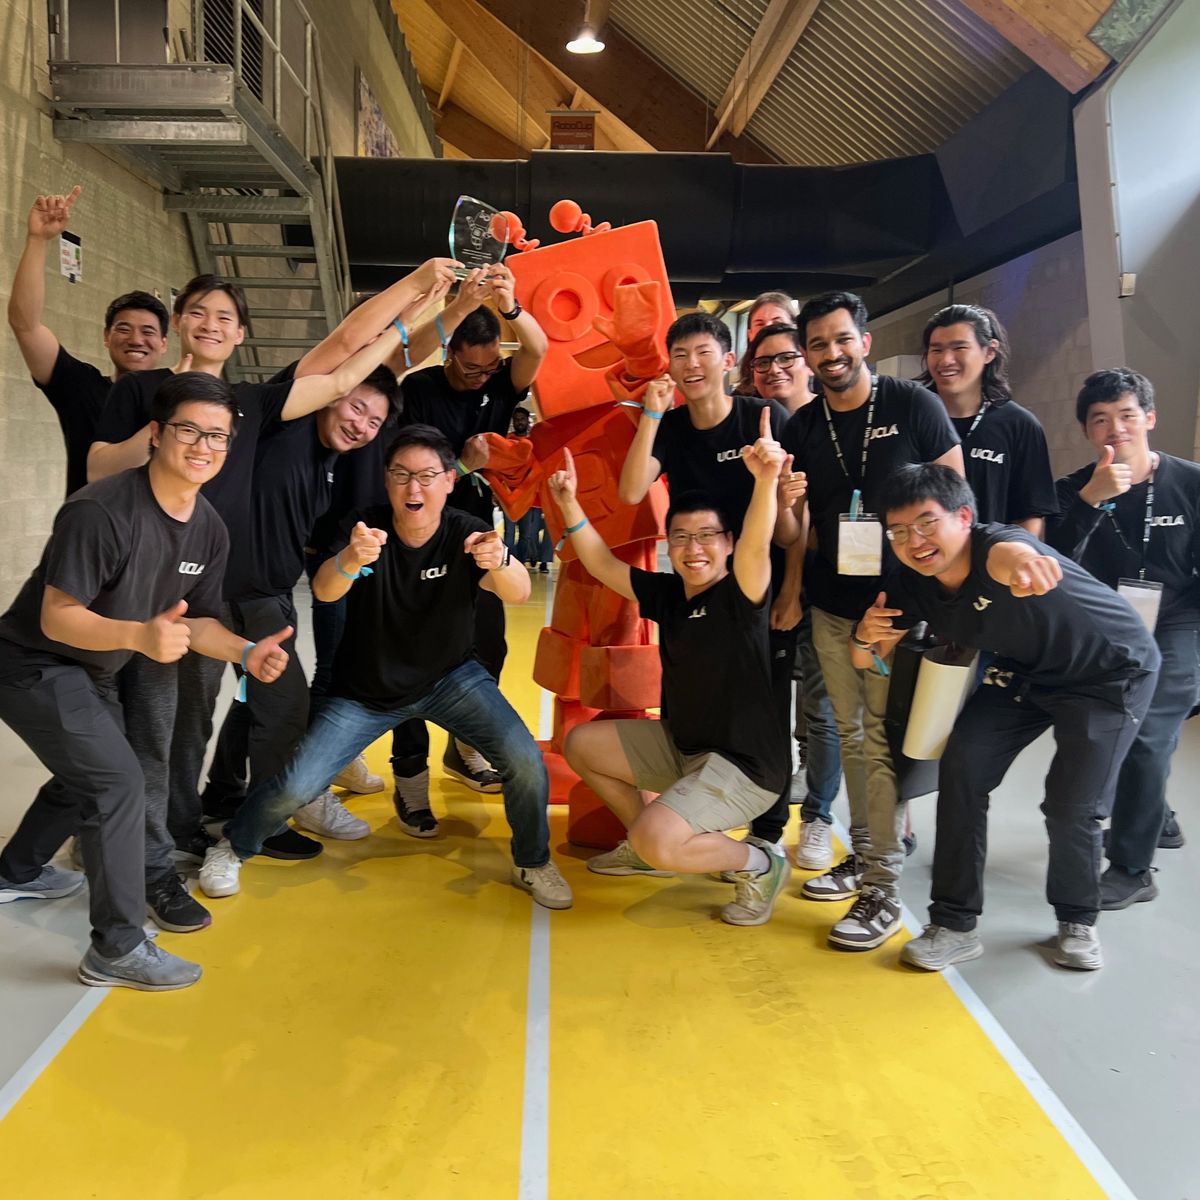
Winning the AdultSize Humanoid League World Championship in 2024 was unforgettable, but what I remember just as much is everything that happened before it: years of development, long days of testing, debugging problems late at night, and working together as a team.
Building robots for others
Robotics has also given me opportunities to help other students build their first robots.
Through projects involving Q8Bot, an open-source quadruped robot, I’ve worked with younger students as they learned mechanical assembly, electronics, programming, and the inevitable art of figuring out why the robot suddenly stopped working.
Teaching robotics has made me better at it too. Explaining why something works often forces me to understand it more deeply myself.
The workshop we built became a co-authored paper, which I presented at UR2026 in Osaka.
Building with a purpose
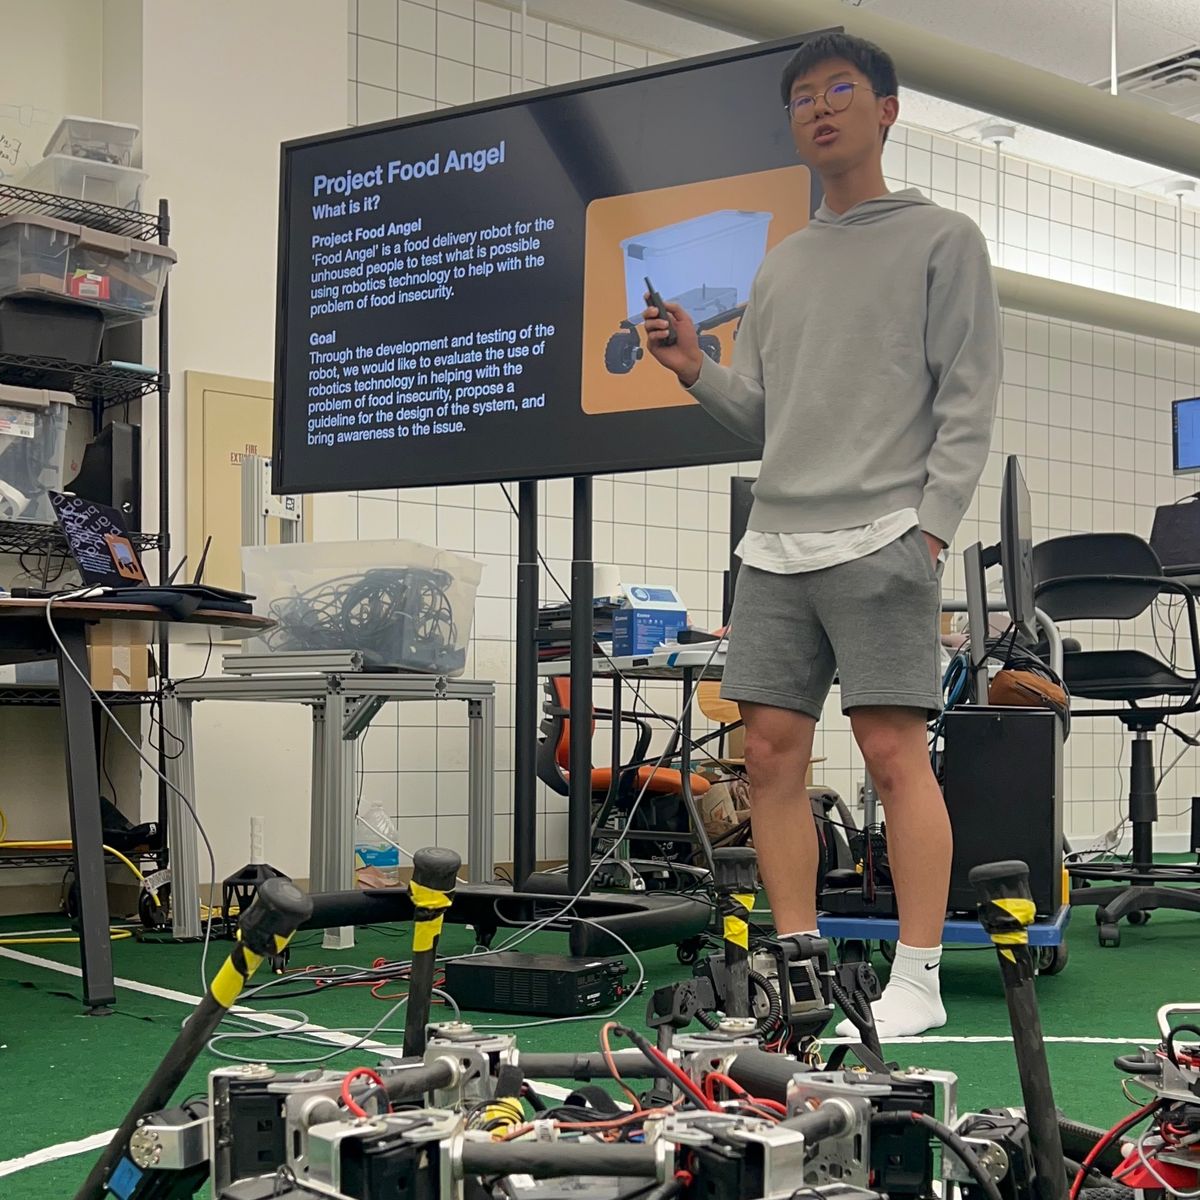
The project that changed how I think about robotics the most is Food Angel.
It taught me that a robot can be technically successful and still be the wrong robot for the people it is supposed to help.
Explore Project Food Angel